
Calibrator
The rationale for calibration
Understand the zero state and the coordinate system
After the robot enters the calibration mode, with all servos rotated to their zero angles, attach the head, tail, and legs prepared in the previous section to the body. They are generally perpendicular to the body frames they are linked to.
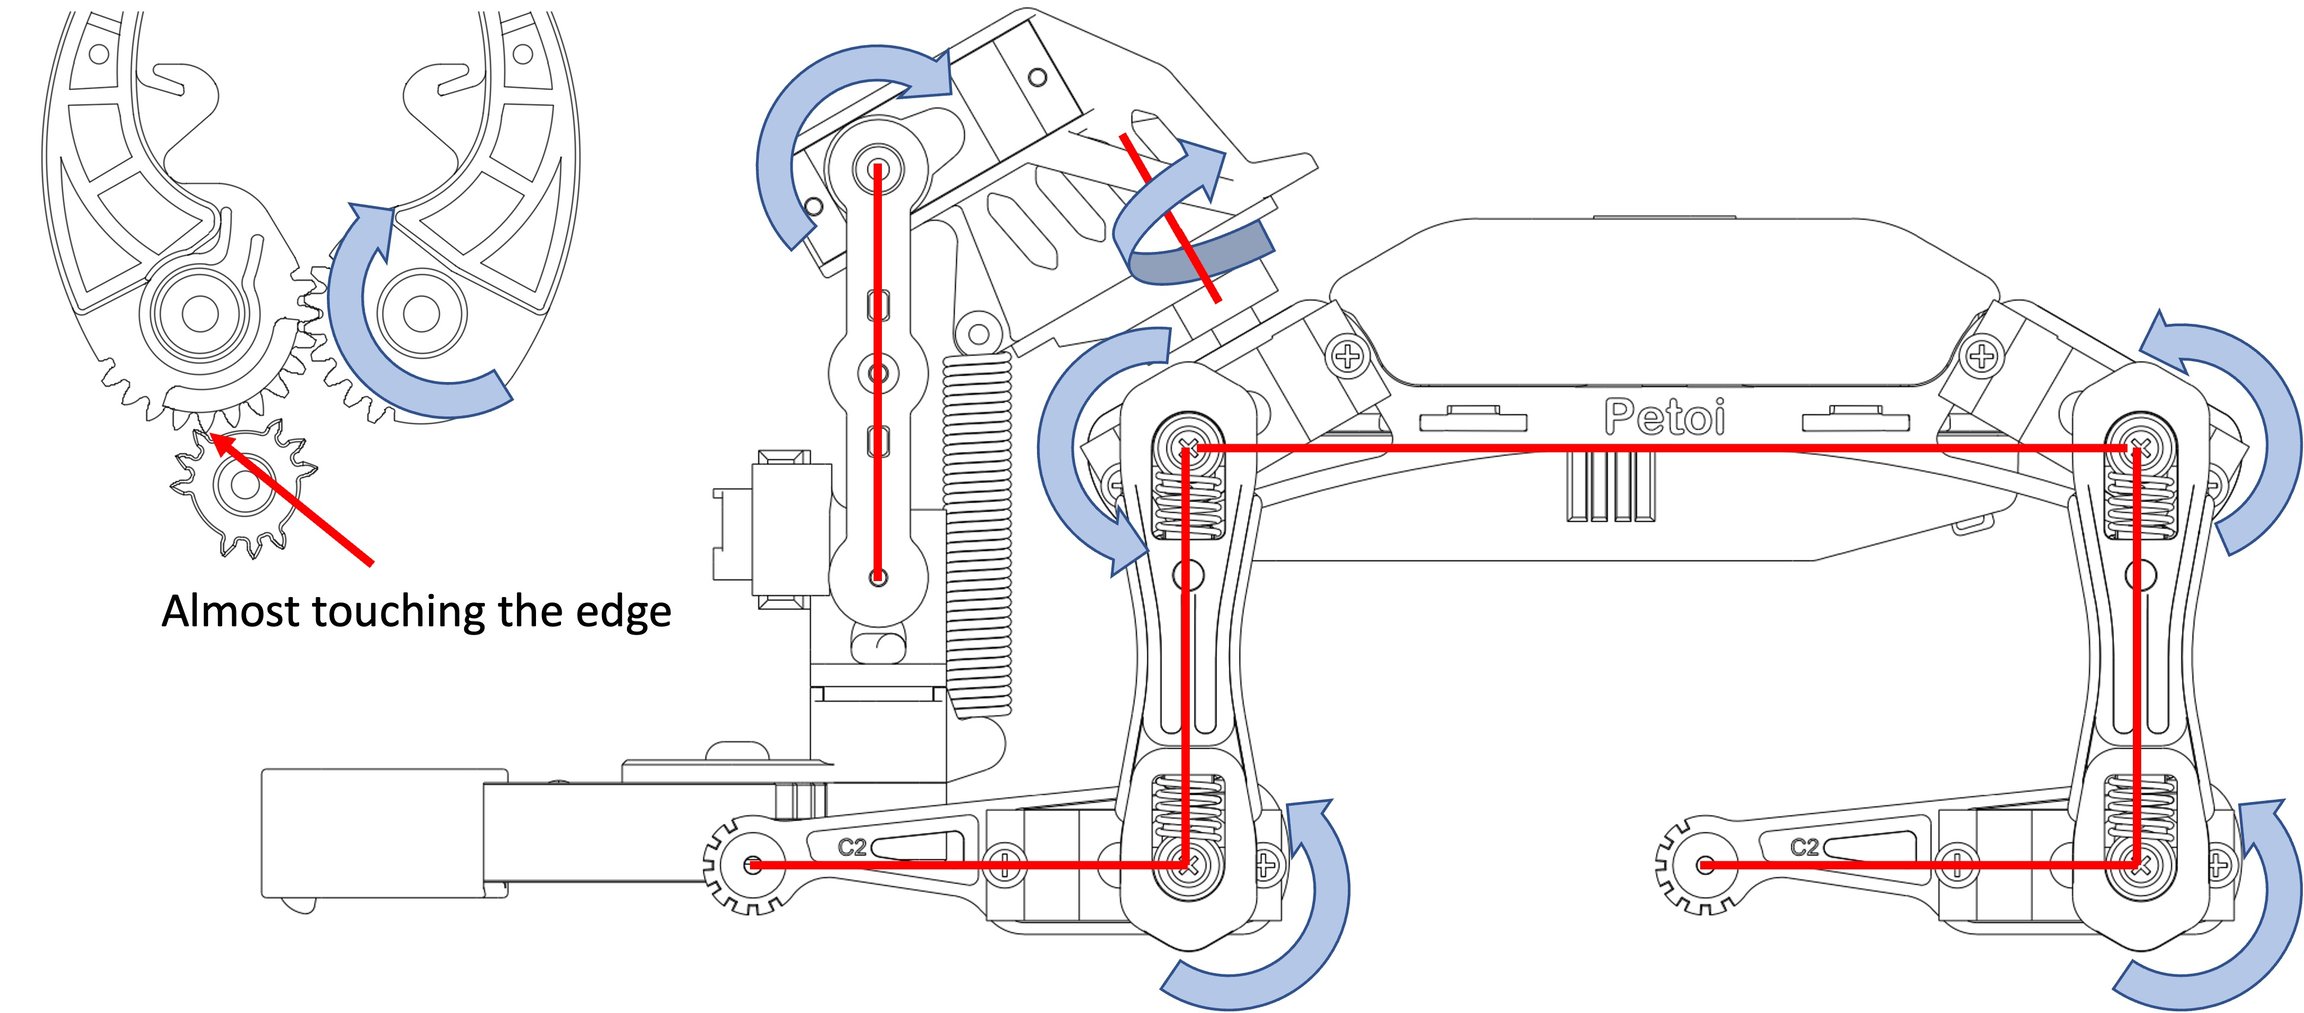
For the construction kit, please install the servo-related components as shown in the picture (calibration mode) and ensure they are perpendicular to each other (the upper leg is perpendicular to the torso, and the lower leg is perpendicular to the upper leg).
Note: Insert the servo-related components directly into the servo output shaft; do not turn the output shaft during this process.
Rotating the limbs counterclockwise from their zero states will be positive (the same as in polar coordinates). Viewed from the left side of the robot's body, the counter-clockwise rotation of the joint is defined as the positive direction.
Discrete angular intervals
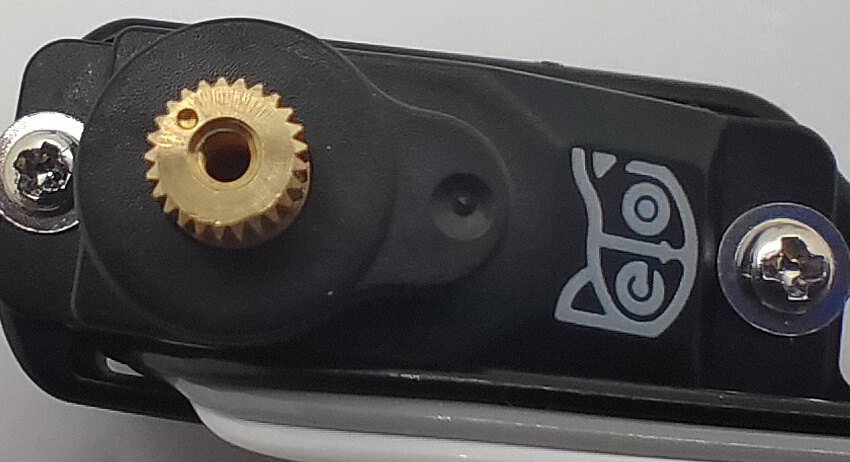
If we look closer at the servo shaft, we can see it has a certain number of teeth. That’s for attaching the servo arms and avoiding sliding in the rotational direction. In our servo sample, the gears divide 360 degrees into 25 sectors, each taking 14.4 degrees(offset of -7.2~7.2 degrees). That means we cannot always get a perfect perpendicular installation.
Calibration Interfaces
The calibrator interface for Bittle X V2+Arm is as follows:

The interfaces above will be displayed when you calibrate for the first time. You can also click to open the upper-right menu in the control panel and select Calibrate to re-access.

Enter the calibration mode
After the robot powers on with the battery, follow one of the two methods to enter calibration mode.
Click the Next step button.

Click the Calibration button in the calibration interface.

For the pre-assembled kit, you can directly power on the robot and use the mobile app to fine-tune all joints.
For the construction kit, after the robot enters the calibration state, do the following steps:
Install the neck servo and leg servos
Note:
You must use the neck section with a J-hook (as pictured below) to prevent the neck from falling when using this robot arm.
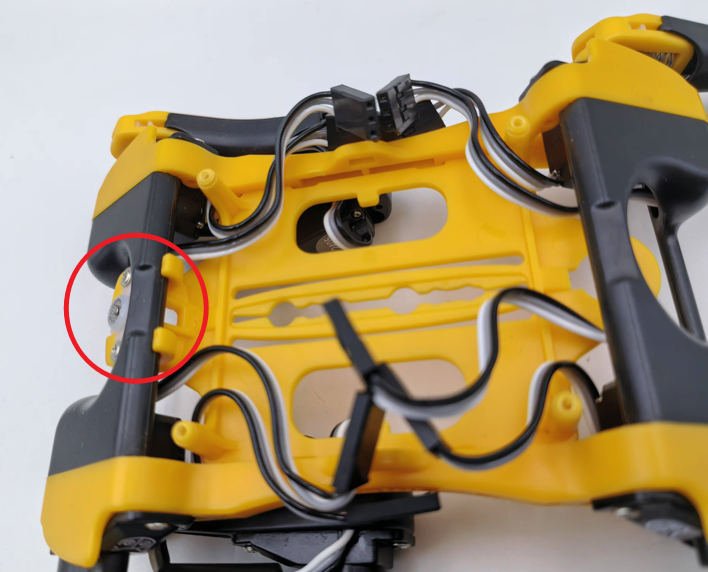

Installing the neck servo is the same as installing the head of Bittle.
Installing the leg servos is the same as installing the legs of Bittle.
Install the robot arm
This robot arm is already fully assembled. After finishing calibrating the neck servo and the leg servos, power off the robot and install the servo slot on the neck servo with two M2*5 self-tapping screws.
Then, power on the robot, and do the joint calibration for the servos on the robot arm.
Use the included L-shaped tool as a reference
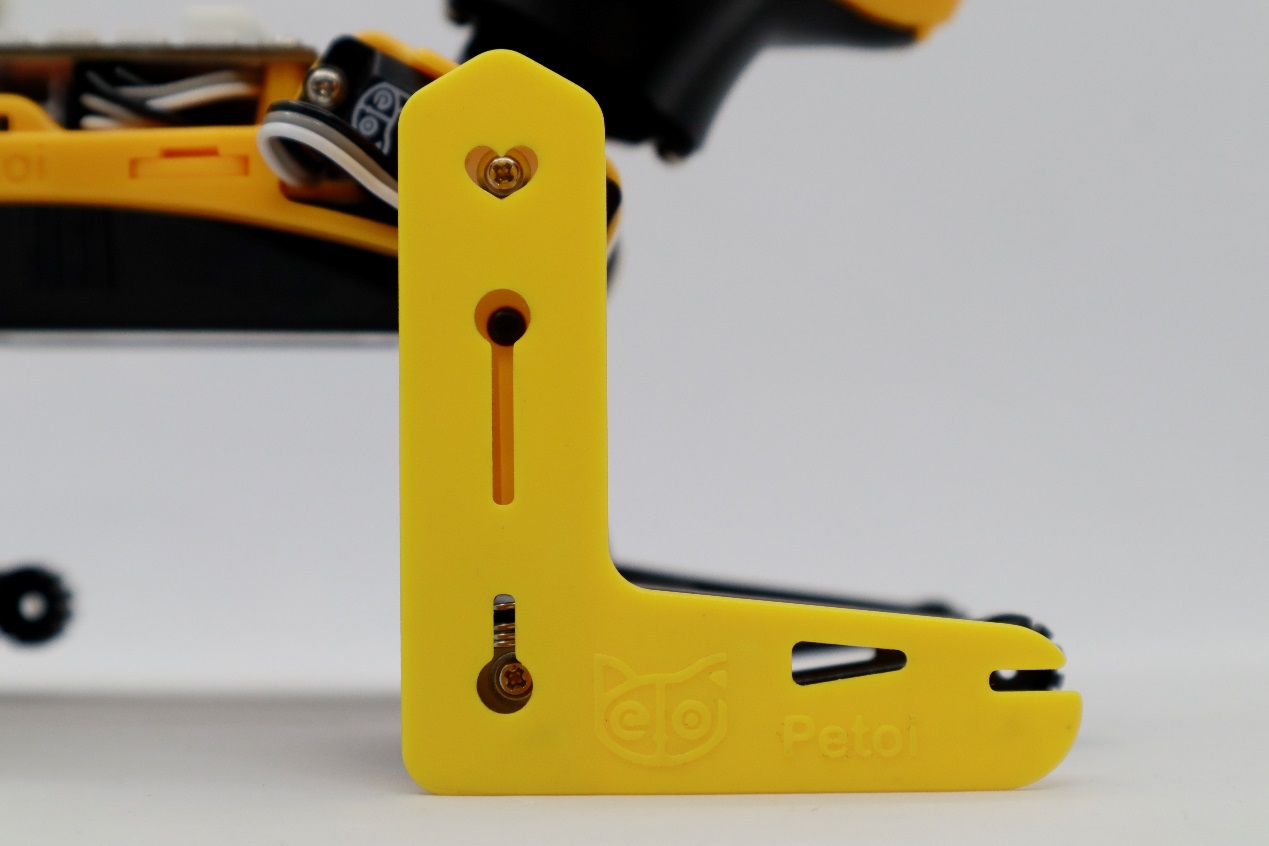
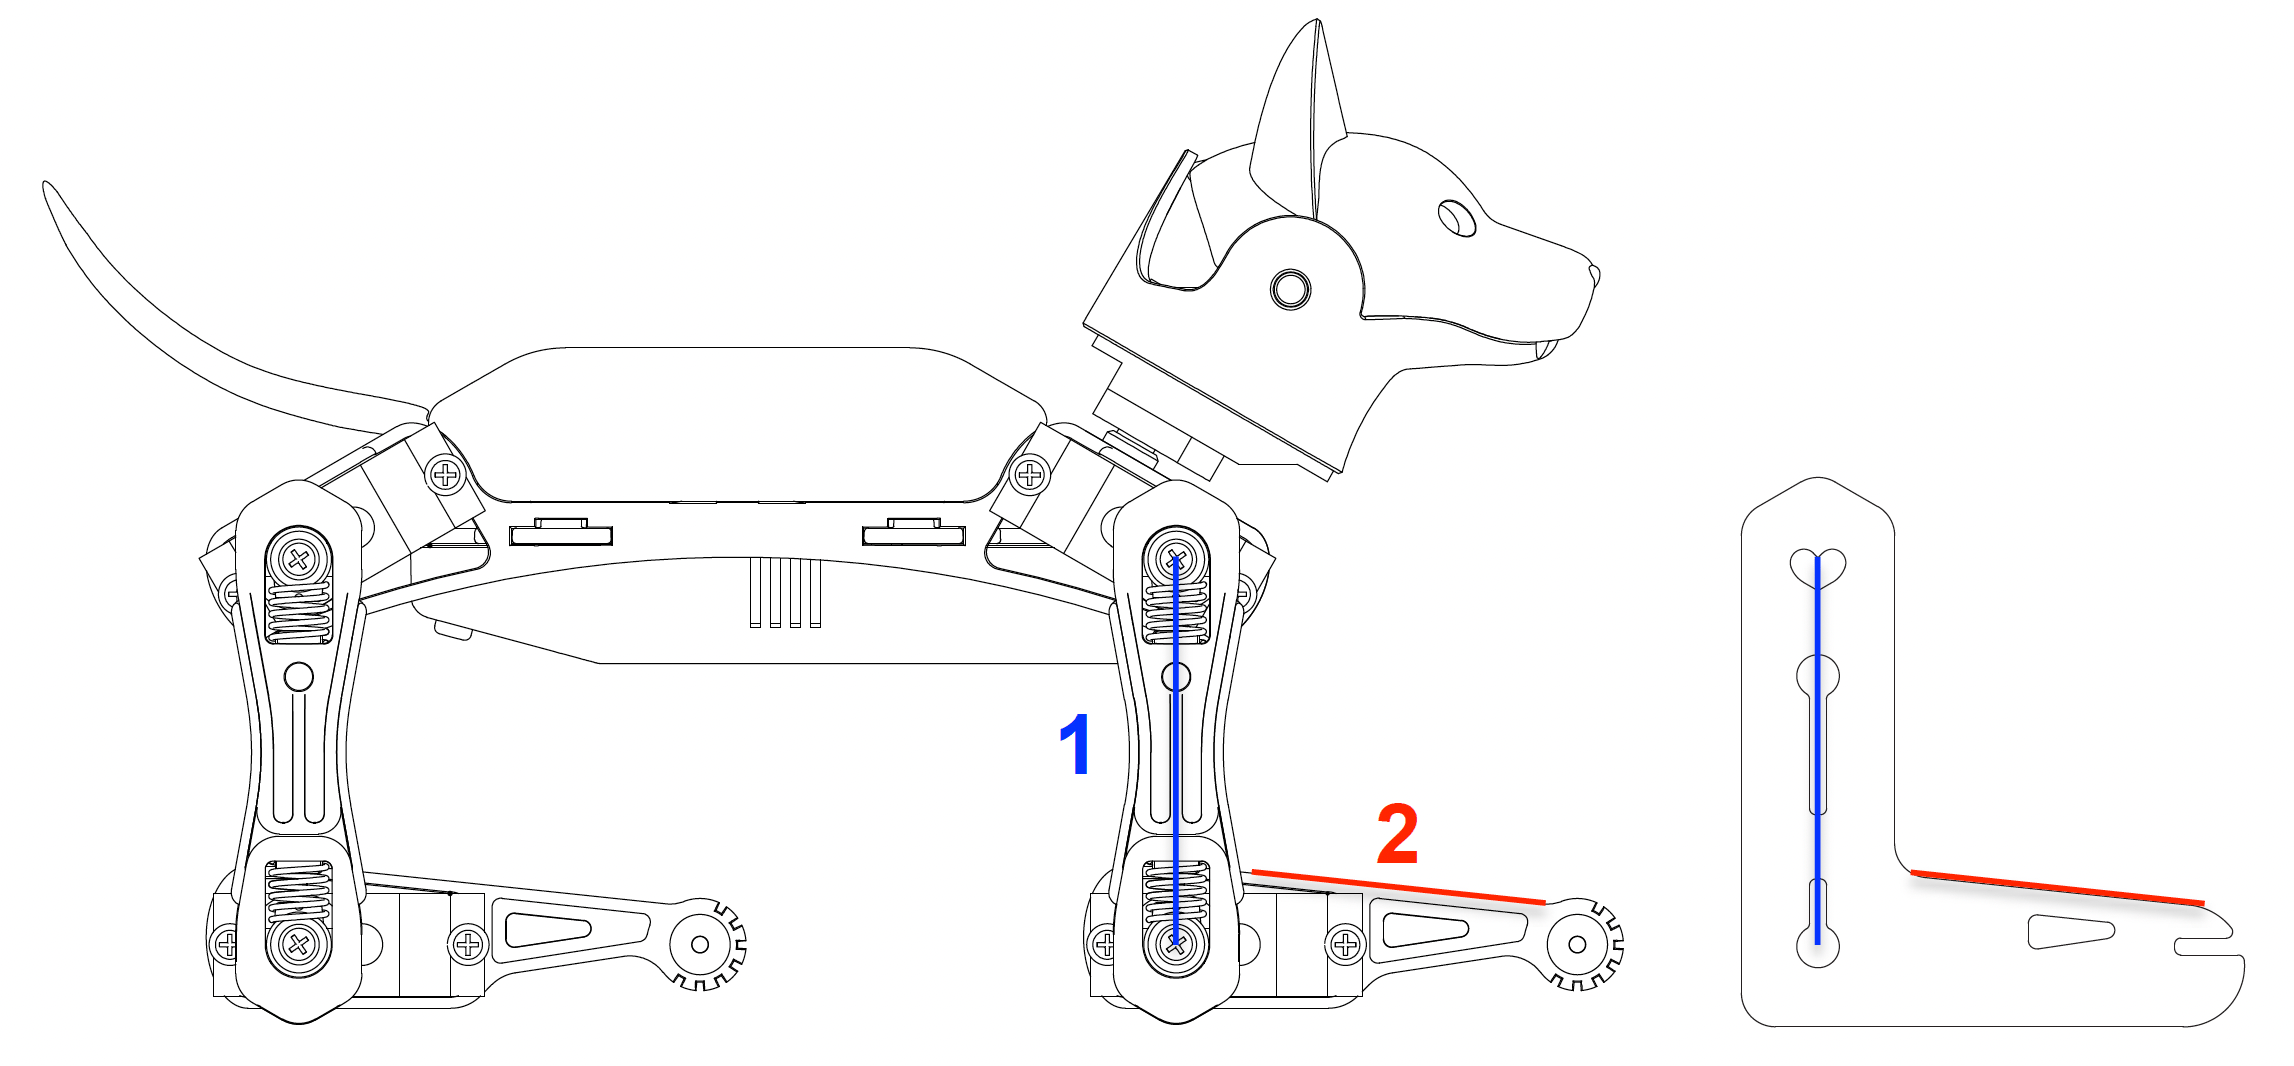
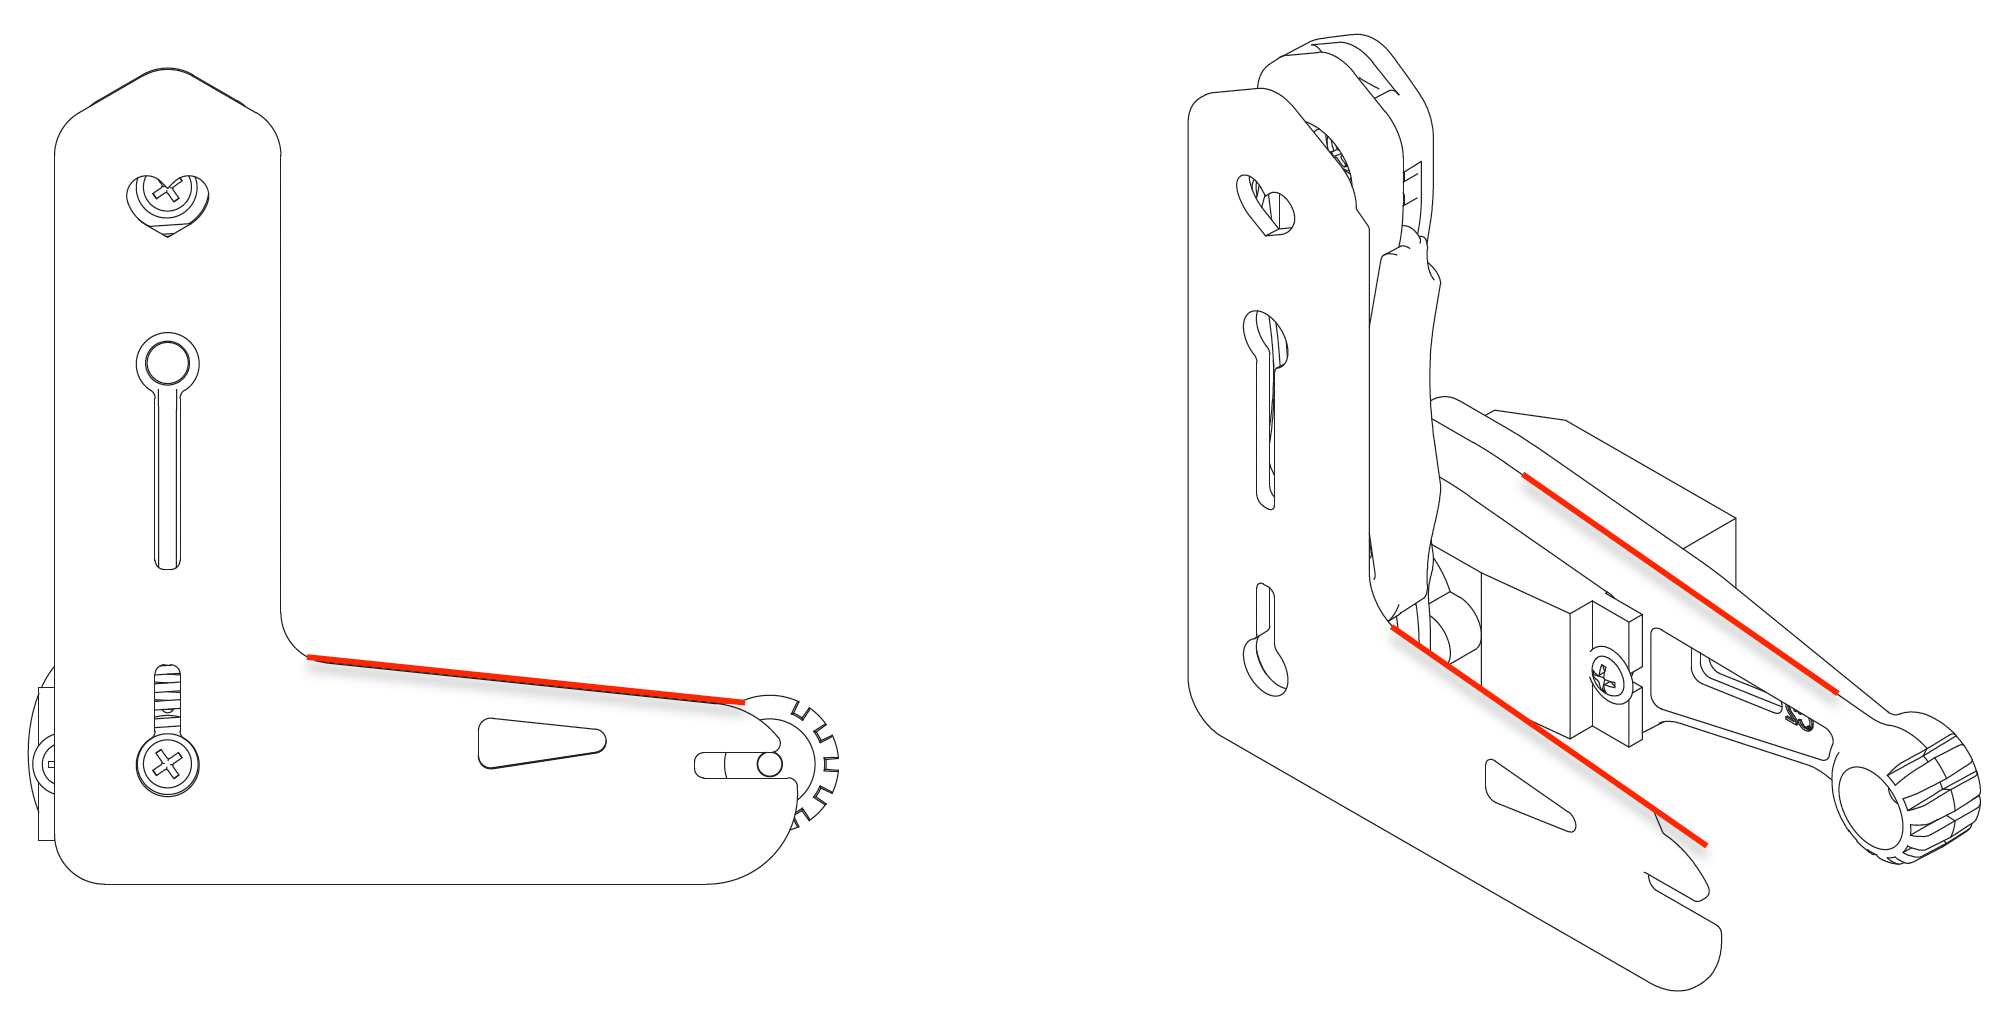

First, select the index number of the joint servo from the diagram(when adjusting the leg servo, adjust the thigh first, and then adjust the calf).
Then, click the "+" or "-" button to fine-tune the joint to the desired angle.
Test the calibration effect

You can click the skill buttons to switch between Rest, Stand, and Walk to test the calibration effect.
If you want to continue calibrating, please click the Calibration button, and the robot will return to the calibration mode, with all servos immediately moving to their calibration positions.
After calibration, remember to click the Save button to save the calibration offset. Otherwise, click "<" in the upper left corner to abandon the calibration.
Install the screws for the construction kit
For the construction kit, after completing the joint calibration, install the center screws to fix the leg parts and neck servo gears.
Last updated